Researchers


CeDiRNet-3DoF — Cloth Grasping in 3DoF
Winning method from the Cloth Manipulation and Perception Challenge at ICRA 2023
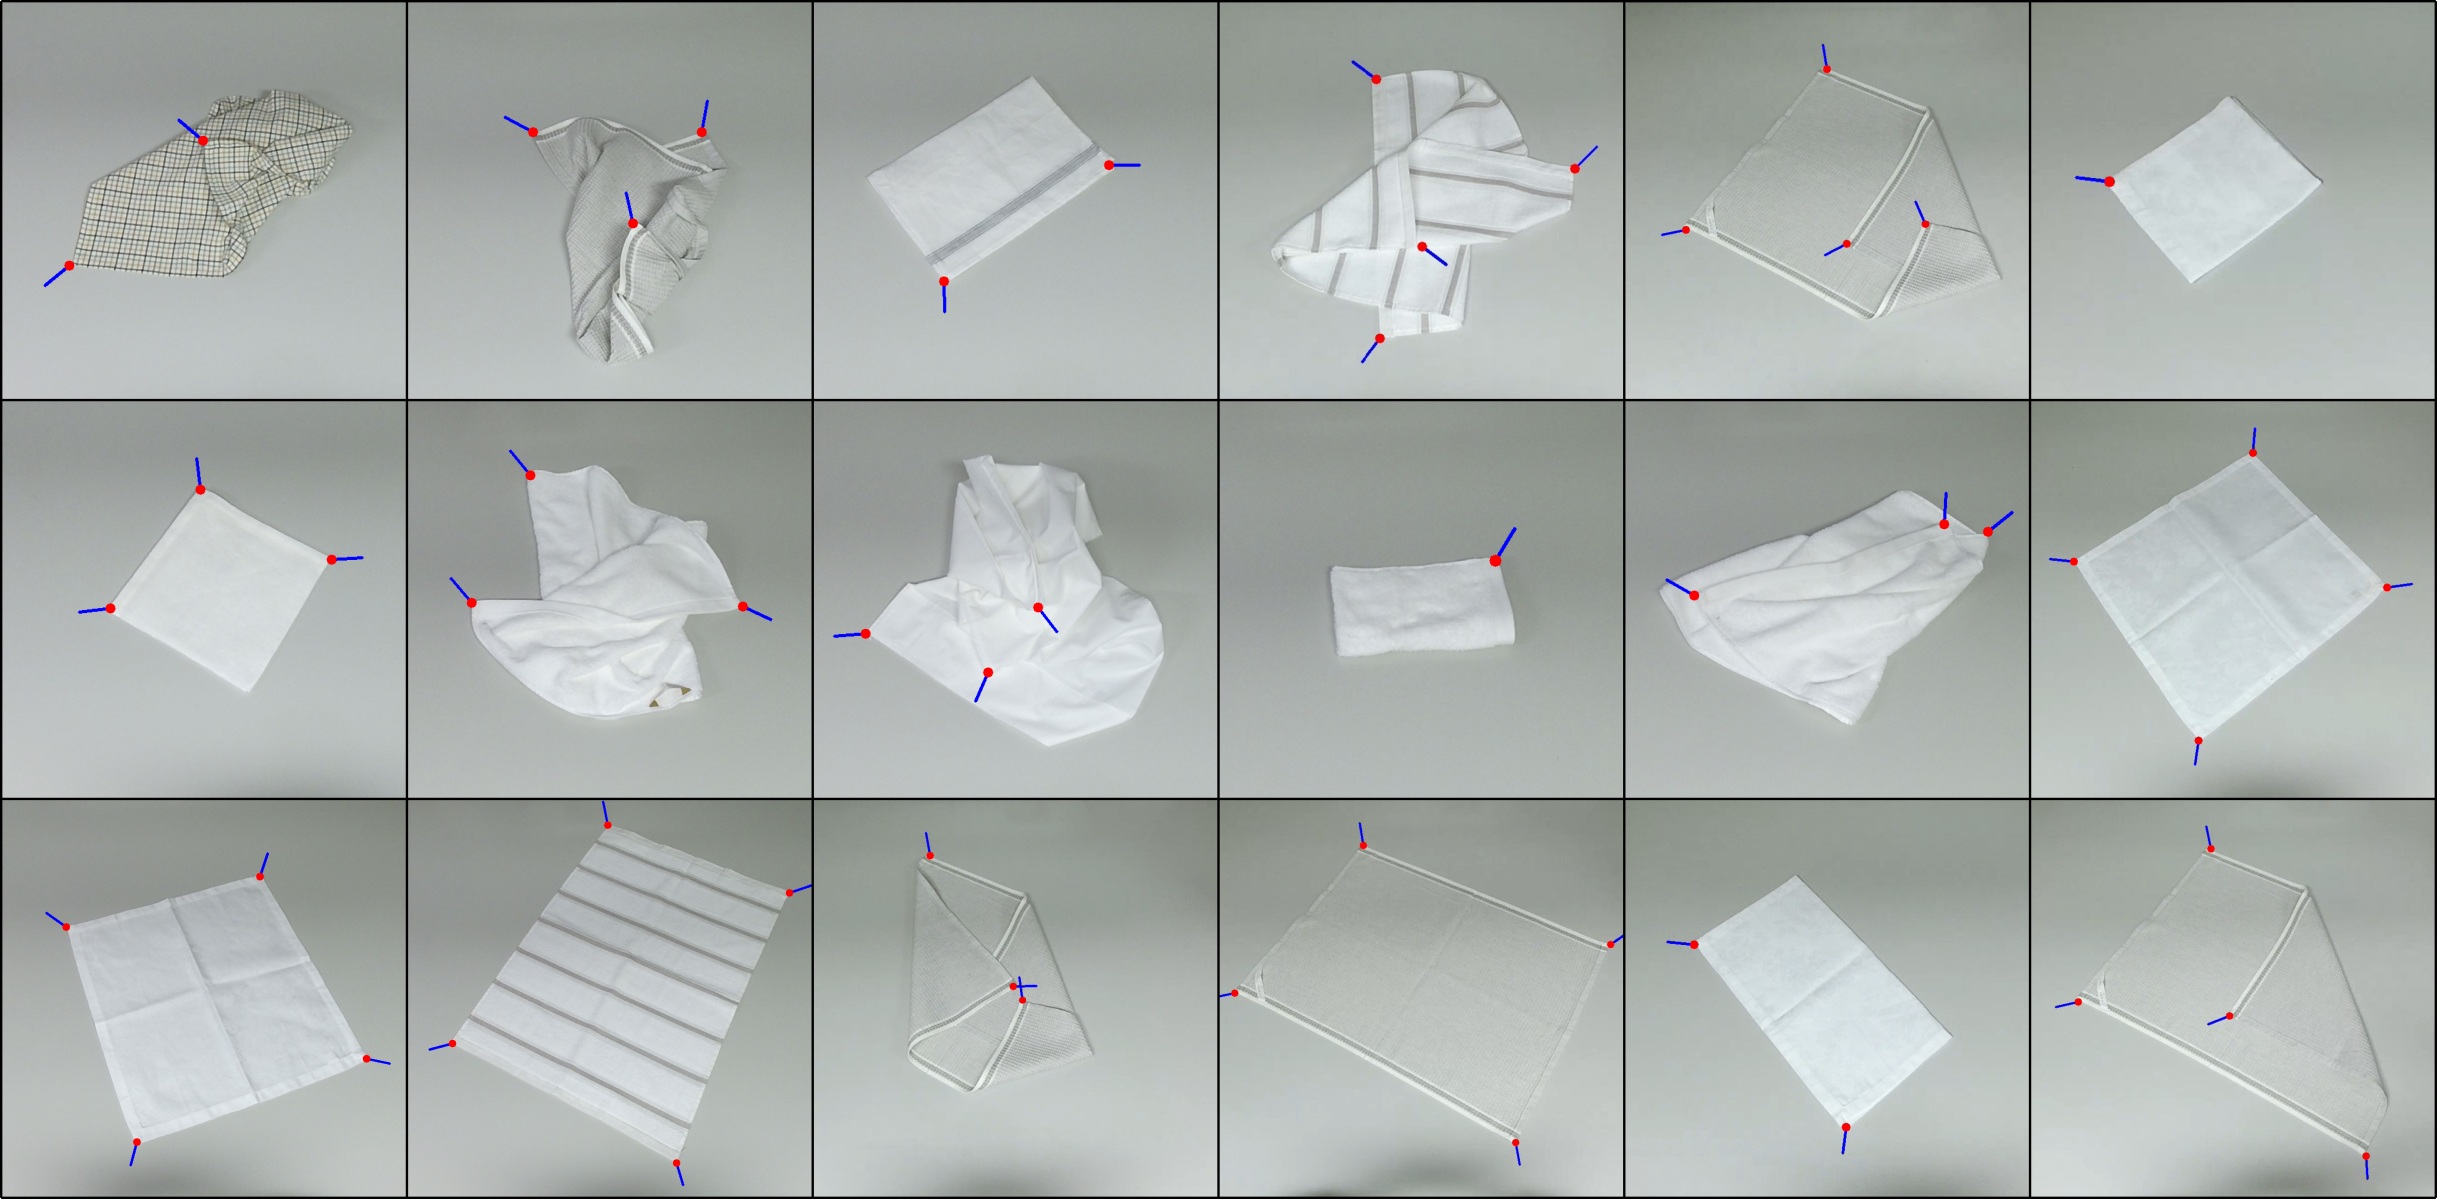
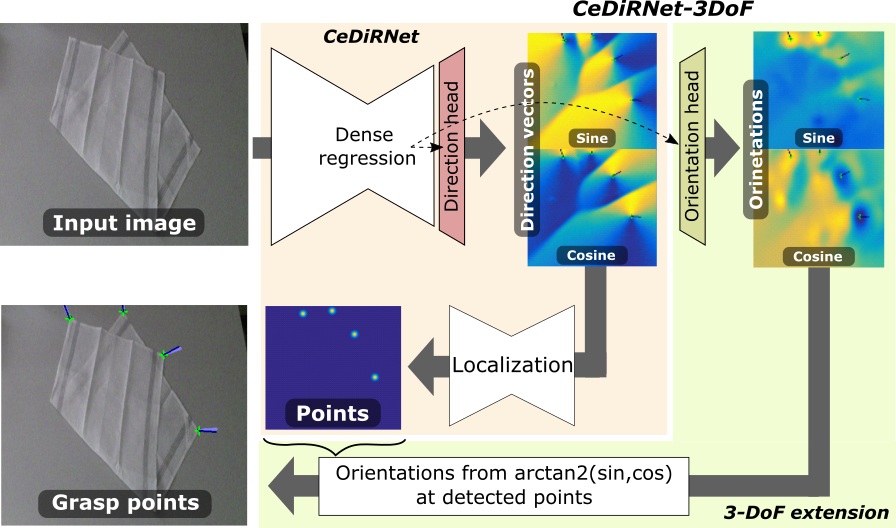
Object grasping is a core challenge in robotics and computer vision, and deformable objects like fabrics present additional complexity due to their non-rigid nature. We present CeDiRNet-3DoF, a deep learning model for grasp point detection that combines center direction regression with regression of the grasp pose angle. Our method achieved 1st place in the perception task of the ICRA 2023 Cloth Manipulation Challenge, while outperforming state-of-the-art approaches in our benchmark, including transformer-based models.
A key contribution of our work is the ViCoS Towel Dataset, a large-scale benchmark for cloth grasping research, enabling fair and consistent evaluation across methods.
 |
 |
 |
|---|
Key Contributions
- CeDiRNet-3DoF: Robust 3DoF grasp point detection for cloth objects based on the CeDiRNet architecture, extended to regress the grasp-pose orientation in one dimension.
- ViCoS Towel Dataset:
- 8,000 real-world RGB-D images.
- 12,000 synthetic images (MuJoCo) for pretraining.
- Multiple towel configurations, lighting conditions, backgrounds, and clutter settings.
- Outperformed current state-of-the-art methods in real-world tests.
Code and models
The implementation of CeDiRNet-3DoF is open-source. Find the code and resources/models on GitHub: CeDiRNet-3DoF Repository
Benchmarking
The ViCoS Towel Dataset provides a standardized benchmark for evaluating cloth grasping methods, addressing the lack of consistency in existing literature and enabling direct comparison of different approaches.
Find the benchmark on GitHub: CeDiRNet-3DoF Benchmark
ViCoS Towel Dataset
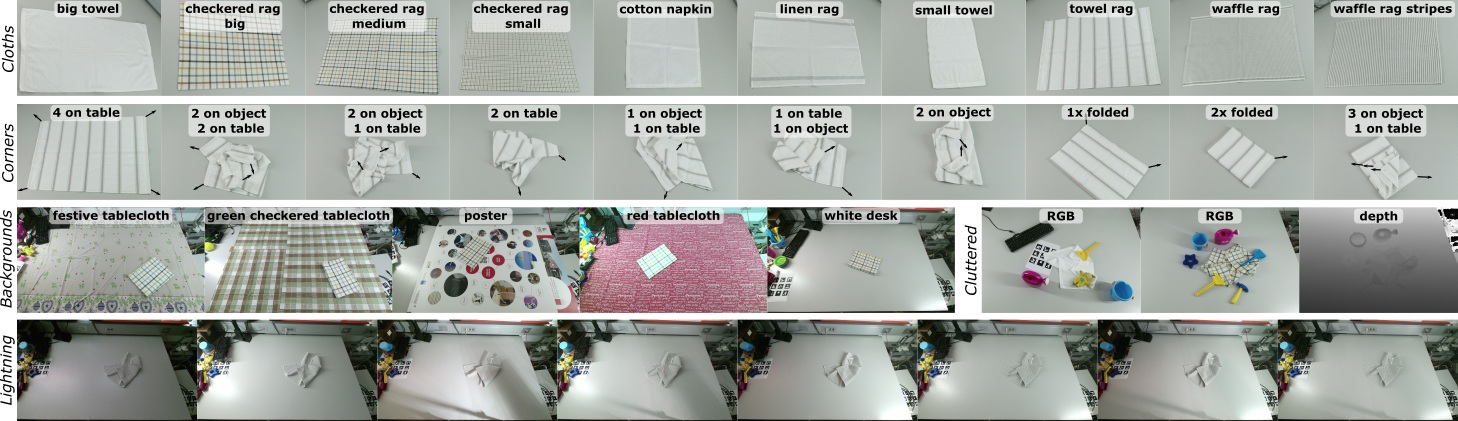
We introduce the ViCoS Towel Dataset for training and benchmarking grasping models, composed of 8,000 RGB-D images of towels in various configurations, lighting, and backgrounds. The dataset includes both real-world samples (8,000) and synthetic data (12,000) generated using the MuJoCo physics engine.
Dataset details:
- 10 towels from Household Cloth Objects
- 10 configurations per towel
- 5 backgrounds
- 8 lighting variations
- With and without clutter
Download — Real-world samples (10 GB)
Download — Synthetic/MuJoCo samples (4 GB)
License and citation
The code and datasets are licensed under the Creative Commons Attribution-NonCommercial-ShareAlike 4.0 International License.

Please cite our paper published in the IEEE Robotics and Automation Letters when using this model and/or dataset:
@article{Tabernik2024RAL,
    author = {Tabernik, Domen and Muhovi{\v{c}}, Jon and Urbas, Matej and Sko{\v{c}}aj, Danijel},
    doi = {10.1109/lra.2024.3455802},
    issn = {23773766},
    journal = {IEEE Robotics and Automation Letters},
    number = {10},
    pages = {8913--8920},
    publisher = {IEEE},
    title = {{Center Direction Network for Grasping Point Localization on Cloths}},
    volume = {9},
    year = {2024}
}